
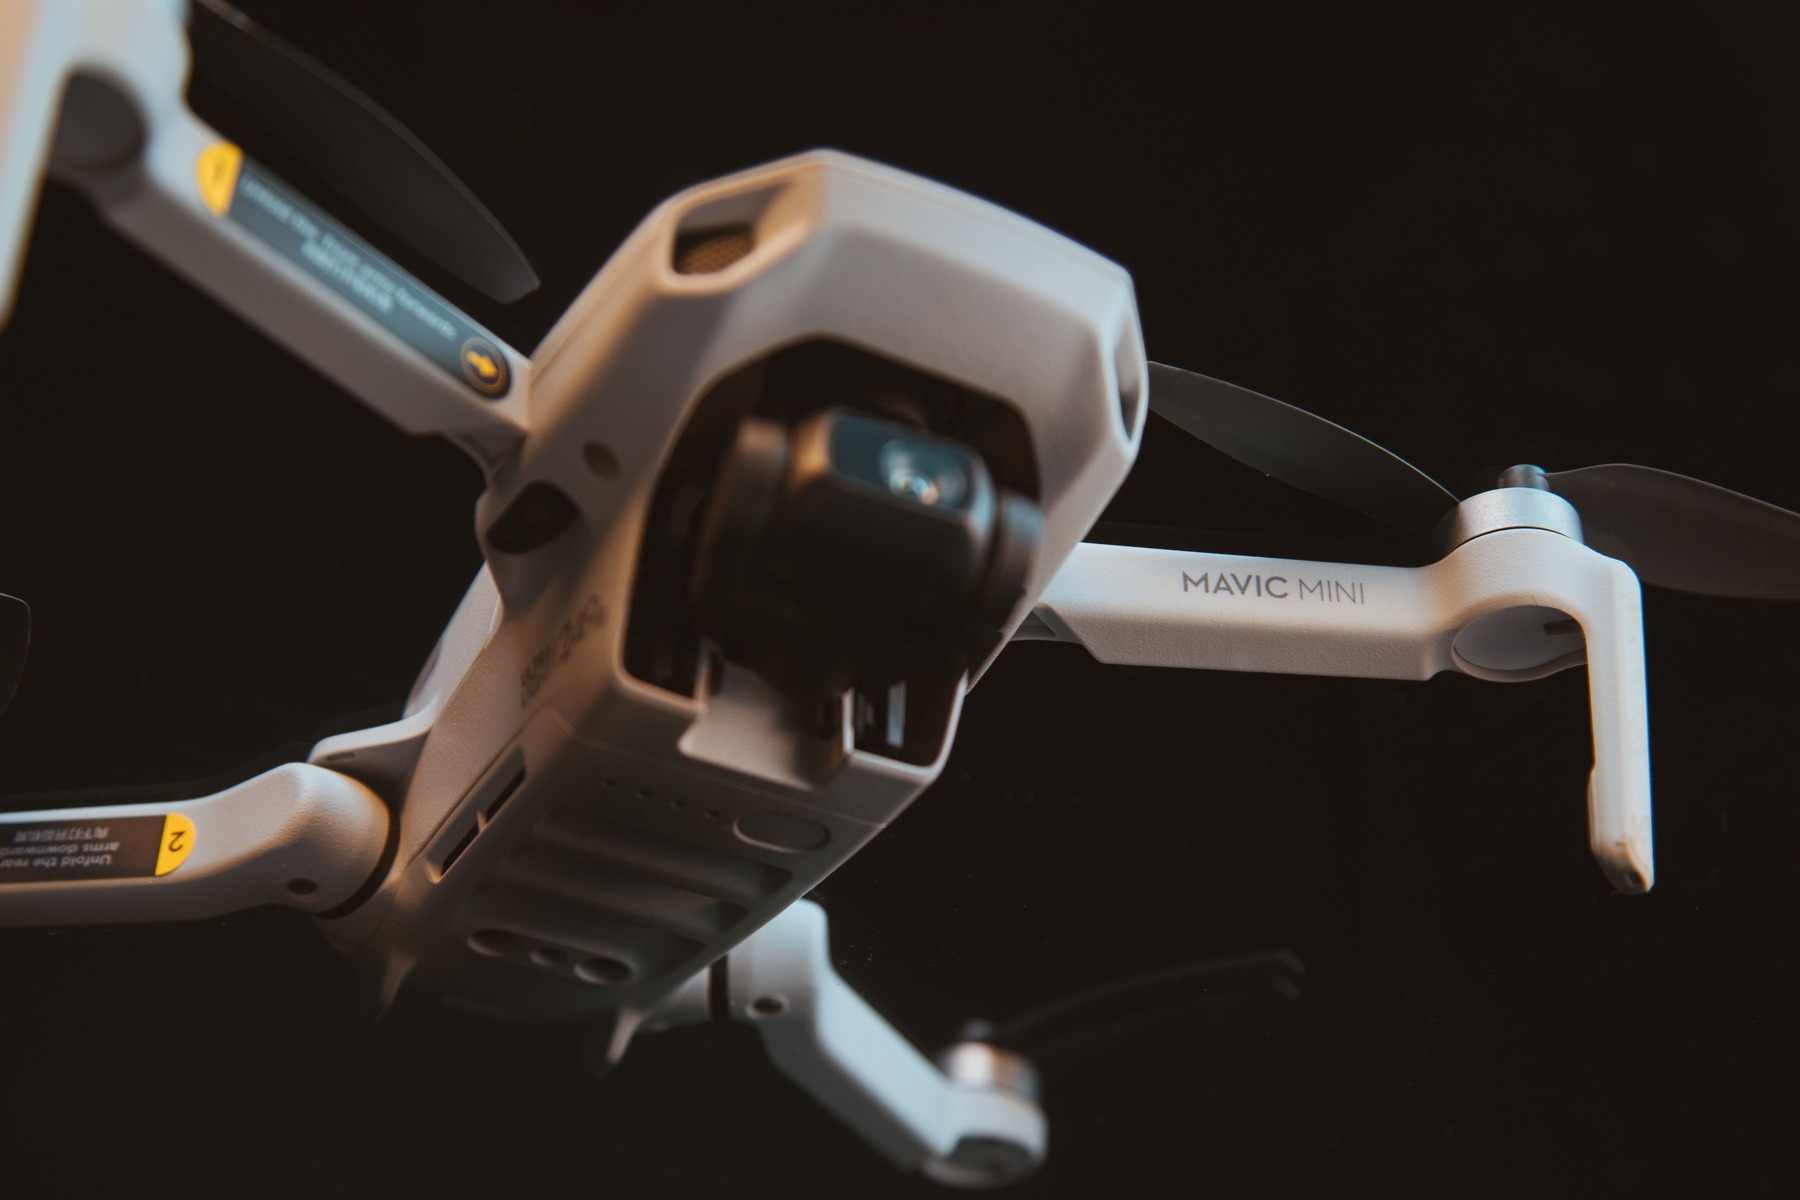
A 44.1-gram quadcopter has learned to do something flying robots normally try to avoid: touch the world around it. Two flexible artificial whiskers point ahead of the rotors. When one brushes a wall, the aircraft estimates where contact occurred, adjusts its motion and begins sliding along the surface.
The system is described by Chaoxiang Ye, Guido de Croon and Salua Hamaza of Delft University of Technology in a Nature Communications study published on September 18, 2026. The researchers demonstrated wall following on hard and textile surfaces in complete darkness, navigation around transparent walls and tactile exploration of a small glass-walled room.
All of the tactile processing and control ran on the drone rather than a nearby computer. The additional algorithms used about 34 kilobytes of RAM. This is one study of a laboratory prototype, not settled evidence that whiskered drones are ready to enter collapsed buildings. What it establishes is narrower and technically useful: a tiny flying machine can use sustained, gentle contact as a primary source of information.
Two wires act as forward-reaching fingers
Each whisker begins as a nitinol wire 200 millimeters long and 0.4 millimeters in diameter. Nitinol is flexible enough to bend against a surface without turning every contact into a collision. The two whiskers are mounted five centimeters apart and angled upward.
At the root of each wire is a resin-filled structure that loosely mirrors a biological follicle. Three BMP390 microelectromechanical barometers sit around that root. Bending the whisker changes the pressure seen by the three sensors in different ways, giving the controller enough information to infer contact depth.
The sensing apparatus weighs 3.2 grams. Once its mounts, wiring and supporting hardware are included, the prototype drone weighs 44.1 grams. The underlying Crazyflie 2.1 Brushless platform has a 100-millimeter frame, which is why “palm-sized” is a fair description even though the whiskers extend well beyond the body.
A long whisker creates a mechanical problem as well as solving a sensing one. Even milli-Newton contact forces can twist a very light aircraft because the wire acts as a long lever. The researchers compared six mounting angles at three flight speeds in 72 trials. Mounts at 30, 45 and 60 degrees completed every trial without a crash, but 45 degrees produced the smallest average peak yaw deviation while preserving more forward reach than 60 degrees.
Propeller wash makes pressure sensing difficult
Barometers are usually associated with altitude. Here they read tiny forces at a whisker root, while sitting inside an especially unfriendly environment. Propellers cool the sensors unevenly, the aircraft vibrates, bent material recovers gradually after contact and the wire can ring when it slides off an edge.
The team developed a drift-correction routine that continually fits the changing baseline over a sliding window of 100 measurements. It updates only while no contact is detected, then applies filtering to suppress high-frequency ringing and delayed recovery. At the contact threshold used in one free-flight test, a simple band-pass filter produced a 38.24 percent false-positive rate and a one-time correction produced 12.23 percent. The recurrent correction produced none in that test.
A compact multilayer perceptron then maps the three pressure channels from a whisker to a one-dimensional contact depth. It has three hidden layers with 32 neurons apiece and 2,273 trainable parameters. A Kalman filter can combine the sensor estimate with a simple model of how the moving drone should change its distance from the wall.
The researchers collected separate datasets against a whiteboard and a glass wall. Each contained 12 flights, with nine used for training and three for testing. The combined model reached a mean reconstruction error of about 4.12 millimeters and a root-mean-square error of 5.75 millimeters in the whiteboard tests. Those are controlled laboratory results, not a claim that every newly built whisker will work that accurately without calibration.
The drone really did follow walls in darkness
For the complete-darkness trials, the aircraft took off, moved forward at up to 20 centimeters per second and entered wall-following mode when a whisker crossed the contact threshold. It tried to keep estimated contact depth between 40 and 100 millimeters for about seven seconds before backing away and landing.
The researchers tested a rigid surface and a soft textile. Whisker estimates broadly tracked a comparison laser on both. The fabric was harder because folds and greater friction disturbed depth estimation and made the controller oscillate, but the drone completed the short wall-following run without crashing.
“Complete darkness” describes the absence of usable vision, not an aircraft operating with no other instruments. The whiskers supplied information about the wall. An inertial measurement unit tracked motion, and a downward-facing time-of-flight sensor supported state and altitude estimation. The comparison laser was recorded during the test, although the authors say its geometry prevented it from serving as definitive ground truth.
The demonstration should also be read at its actual scale. These were approximately seven-second interactions with prepared surfaces, not long flights through smoke, rubble or an unfamiliar cave. The result is still notable because maintaining stable contact is harder for a flying body than for a wheeled robot resting on the ground.
Transparent walls exposed a different advantage
Darkness is not the only situation in which sight can fail. Clear acrylic can be difficult for an optical rangefinder because light may pass through, reflect at an awkward angle or return an intermittent signal. Touch does not have to decide whether a surface looks solid.
In two arrangements of three transparent walls, the drone flew forward until a whisker made contact, followed the wall and resumed forward motion after clearing it. Five flights were conducted for each arrangement. The aircraft avoided the obstacles and reached the target in every reported trial.
Those flights fused inertial and optical-flow data for the drone’s own state estimate. The environmental decision to follow or leave a wall came from tactile contact. That separation is central to the study: the researchers did not discard every optical component on the aircraft; they replaced visual obstacle perception with touch.
The approach grows out of the group’s earlier biomorphic whisker sensor, which located contact points while mounted in a controlled apparatus. The new work moves that sensor family into closed-loop flight, where every reading can alter the vehicle that is generating the vibration and airflow around it.
What fits inside 34 kilobytes
The headline memory figure is accurate, but it needs a denominator. The STM32F405 flight controller has 192 KB of RAM. The base Crazyflie firmware occupies about 132 KB. The whisker-based autonomy adds roughly 34 KB and leaves about 26 KB free.
Within that additional budget, the drift-correction module needs about 0.2 KB. The tactile depth estimator, including neural-network and Kalman-filter parameters, occupies about 9.6 KB. The mapping and active-perception module is the largest component at about 20.9 KB, using no more than 50 training points on a coarse 10-by-10 grid.
Some working memory can be reused because depth estimation and active mapping do not execute simultaneously. Basic tactile sensing and control run at 50 hertz. Updating the full map with 50 points takes about 0.29 seconds, so that slower operation is triggered intermittently rather than during every control cycle.
Thirty-four kilobytes is less data than many low-resolution JPEG photographs occupy as files. That comparison conveys scale, but it is not a direct measurement of equivalent complexity. RAM is temporary working space and a JPEG is compressed stored data. The meaningful engineering point is that perception, estimation, mapping and control fit beside the existing flight software on a small microcontroller.
Touch can make a rough map, with limits
Simple wall following can trap a robot in concave corners or send it around irrelevant contours. To explore rather than merely trace, the researchers used a Gaussian-process surface model. The drone samples contacts, estimates a boundary and chooses uncertain areas to investigate, while a corner penalty steers it away from high-curvature regions likely to cause a crash.
In ten simulated rooms with randomly rotated layouts, the full method found the exit nine times within five minutes. The mean travel distance was 25.38 meters. The reconstructed boundaries remained coarse, with mean errors of 0.26 meters by one metric and 0.14 meters by another.
The team also built a two-by-two-meter glass-walled room with an 80-centimeter exit. A real drone began by probing four directions, followed walls to gather contour points, updated its map and eventually left through the opening. Optical flow provided egomotion and stabilization, while touch supplied the environment measurements used for navigation decisions.
The complete system is available in the researchers’ public code and data repository. That matters because the 34 KB claim depends on implementation choices such as fixed grid size, bounded datasets and reuse of temporary memory, not simply on choosing a small neural network.
The cost is endurance and calibration
The tactile package is light, but it is not free. The aircraft flew for 11.26 minutes with no extra payload, 8.52 minutes with the whisker hardware and wiring, and 7.18 minutes when the onboard tactile pipeline was also active. The full configuration therefore cut endurance by about 36 percent.
Manufacturing variation remains another obstacle. The authors report that the best performance currently requires about five or six controlled sweeps with an external reference for each device, taking roughly 15 to 20 minutes. Drift can accumulate during long contact, and performance degrades as surfaces become more curved or begin moving.
Two forward-facing whiskers can also miss hazards at the sides. The corner-aware planner reduces one failure mode but does not turn the aircraft into an all-direction tactile sensor. Search and rescue, inspection and cave exploration are possible applications, not tasks demonstrated under operational conditions in this paper.
ScienceBlog has covered other attempts to borrow mechanics from animals, including a bat-inspired gripper that lets a drone perch without running its motors and a liquid-metal skin that lets an underwater wing sense its own deformation. The whiskers belong to the same broader shift: making the body part of the sensing system rather than treating contact as failure.
A second sense, not a replacement for sight
Cameras remain far richer than two wires. Lidar can measure open space without touching it. Radar reaches through conditions that defeat ordinary vision. The case for whiskers is not that one tactile channel should replace them all.
Touch supplies a different kind of certainty. A clear sheet that confuses a laser is still solid when a wire bends against it. A black room that gives a camera no usable photons still has walls. On a very small aircraft, the sensor can be lighter and computationally cheaper than a more elaborate perception stack.
The prototype’s achievement is therefore modest in distance and ambitious in integration. It followed prepared surfaces for seconds, mapped one small enclosure and spent a third of its possible flight time carrying and running the system. Yet the sensing, estimation and decisions happened onboard. The drone did not see the wall in the dark; it remained airborne while feeling where the wall began.